TASK 20 / HTML · V1 · Engineering tool

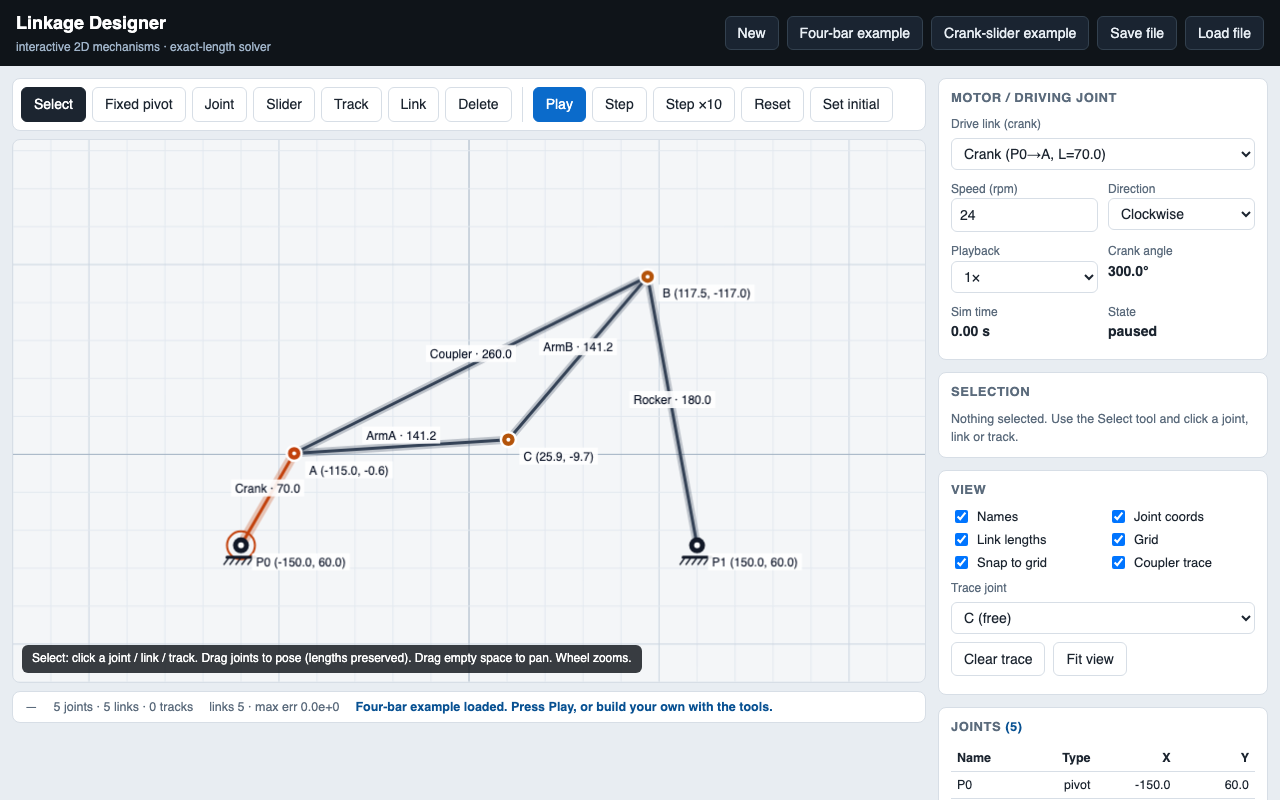
2D Mechanical Linkage Designer

二维机械连杆设计器

2 runs · 20.A.01 · HTML

Compare works →
TASK 20 · 20.A.01 · HTML2D Mechanical Linkage Designer
Open independent copy ↗
2D Mechanical Linkage Designer

Preview note: 模块化入口 index.html + 单文件构建 dist/linkage-designer.html

ORIGINAL PROMPT

Original prompt

PROMPT/PHASE2_30_ADVANCED_CREATION_PROMPTS_BILINGUAL.md · The original prompt is kept verbatim

Source ↗
ORIGINAL PROMPT

Original prompt

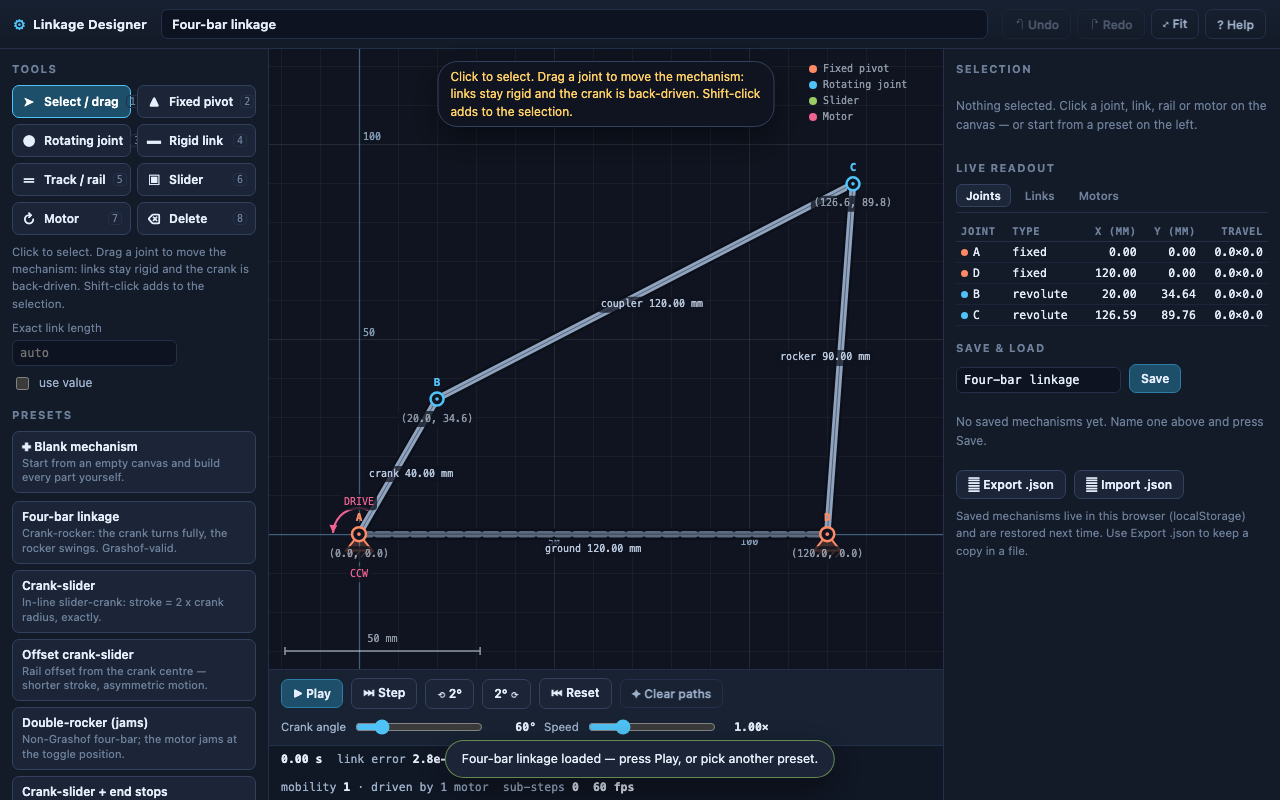
Build an interactive 2D mechanical linkage designer.

Users should be able to:
- create fixed pivots
- create rotating joints
- create rigid links with exact lengths
- create sliders constrained to tracks
- connect components into mechanisms
- choose a driving joint or motor
- play, pause, reset, and step the simulation
- display joint coordinates and link lengths
- save and reload mechanisms

Support at least:
- a four-bar linkage
- a crank-slider mechanism

Rigid links must preserve their lengths throughout the simulation, and constrained joints must remain attached.
TRANSLATION

Chinese translation

构建一个交互式二维机械连杆设计器。用户可以创建固定转轴、旋转关节、具有精确长度的刚性杆件、受轨道约束的滑块,并将它们连接为机械机构;可选择驱动关节或电机,支持播放、暂停、重置、单步,显示关节坐标与杆长,并保存/加载机构。至少应支持四连杆机构和曲柄滑块机构。整个模拟过程中刚性杆长度必须保持不变,受约束关节不能脱离连接。

Expected outcome

The deliverable should be a geometric-constraint-based mechanism simulator rather than a frame-by-frame decorative animation. Link lengths, pivots, and slider tracks should remain continuously constrained while a driven joint causes the rest of the mechanism to solve accordingly. Four-bar and crank-slider mechanisms should move stably and expose useful measurements and joint trajectories.

Additional verification guidance

  • Sample rigid-link lengths throughout the motion cycle and confirm errors remain within a reasonable tolerance.
  • Run four-bar and crank-slider mechanisms and verify that joints remain attached and sliders stay on their tracks.
  • Pause and step the mechanism, confirming step results match continuous simulation at equivalent states.
  • Save and reload mechanisms and verify geometry, connections, drive settings, and dimensions restore completely.
THREE INTERPRETATIONS

Same task, three model interpretations

All three results use the same width and the same preview ratio; no model is marked as best.

GPT-5.6 Sol—
Not archived yetThis model has not completed this task in Archive 001.
K3—
Not archived yetThis model has not completed this task in Archive 001.
COMPARISON METRICS

Comparison metrics

Cross-model comparison must note differences in harness, budget and isolation.

MetricDeepSeek-V4.1-Flashrun-deepseek-v4-1-flash-exp-0910-task-20-r1Muse Spark 1.3run-muse-spark-1-3-xhigh-task-20-r1GPT-5.6 SolNot archived yetK3Not archived yet
Runtime28:486:13——
API calls123Not recorded——
Tool calls12534——
Failures / retries00——
Token throughputNot recorded146.8K——
AI review96/10092/100——
RUN RECORDS

Run records

Two runs of the same task version can be compared side by side.

20.A.01 · run-deepseek-v4-1-flash-exp-0910-task-20-r1DeepSeek-V4.1-Flash● Archived
Runtime
28:48
Token throughput
Not recorded
API calls
123
View archive record →
20.B.01 · run-muse-spark-1-3-xhigh-task-20-r1Muse Spark 1.3● Archived
Runtime
6:13
Token throughput
146.8K
API calls
Not recorded
View archive record →
RELATED TASKS

Related tasks

View all tasks →